Contact-Aware Incremental Model Predictive Control for an Underactuated Aerial Manipulator
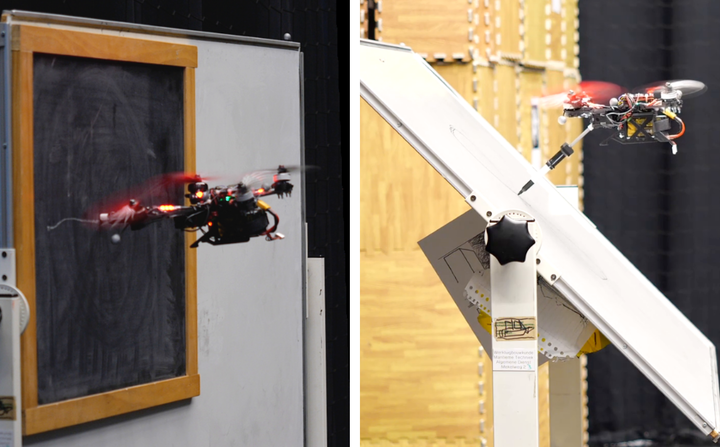 Aerial writing experiments on a blackboard and on inclined and vertical whiteboards.
Abstract
We develop a controller that lets an underactuated quadrotor with a rigid one-joint arm write on surfaces while maintaining tool position and contact force. Nonlinear model predictive control plans the contact motion, and whole-body incremental nonlinear dynamic inversion compensates for disturbances. Simulations and flight experiments test writing on vertical and tilted surfaces under varying friction, force targets, and wind. The system tracks five end-effector pose coordinates alongside contact force using a simple aerial manipulator without a force/torque sensor.
Type
Publication
IEEE Robotics and Automation Letters
Darwin Liu
PhD student