I actively supervise MSc students from TU Delft. If you are interested in design, learning, planning, control, and perception of aerial robots, please contact me at s.sun-2@tudelft.nl. NB: Please attach your transcript, CV, and motivation letter.
Current Members
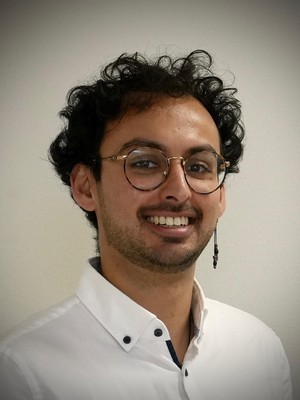
Henry Adam
MSc student
Multi-agent perception

Burak Gyuler
MSc student
Cooperative aerial manipulation

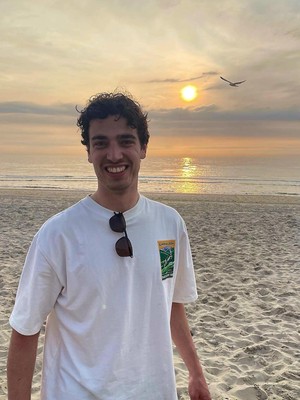
Paco Pronk
MSc student
Imitation learning for CAMLs
Visitors
Alumni
Jack Zeng
MSc graduate (Cum Laude)
Decentralized cooperative aerial manipulation, Now PhD student at EPFL