HARPA is hiring at TU Delft
Two PhD positions, one postdoc position, and one engineer position are open at TU Delft.
EIC Pathfinder Challenge
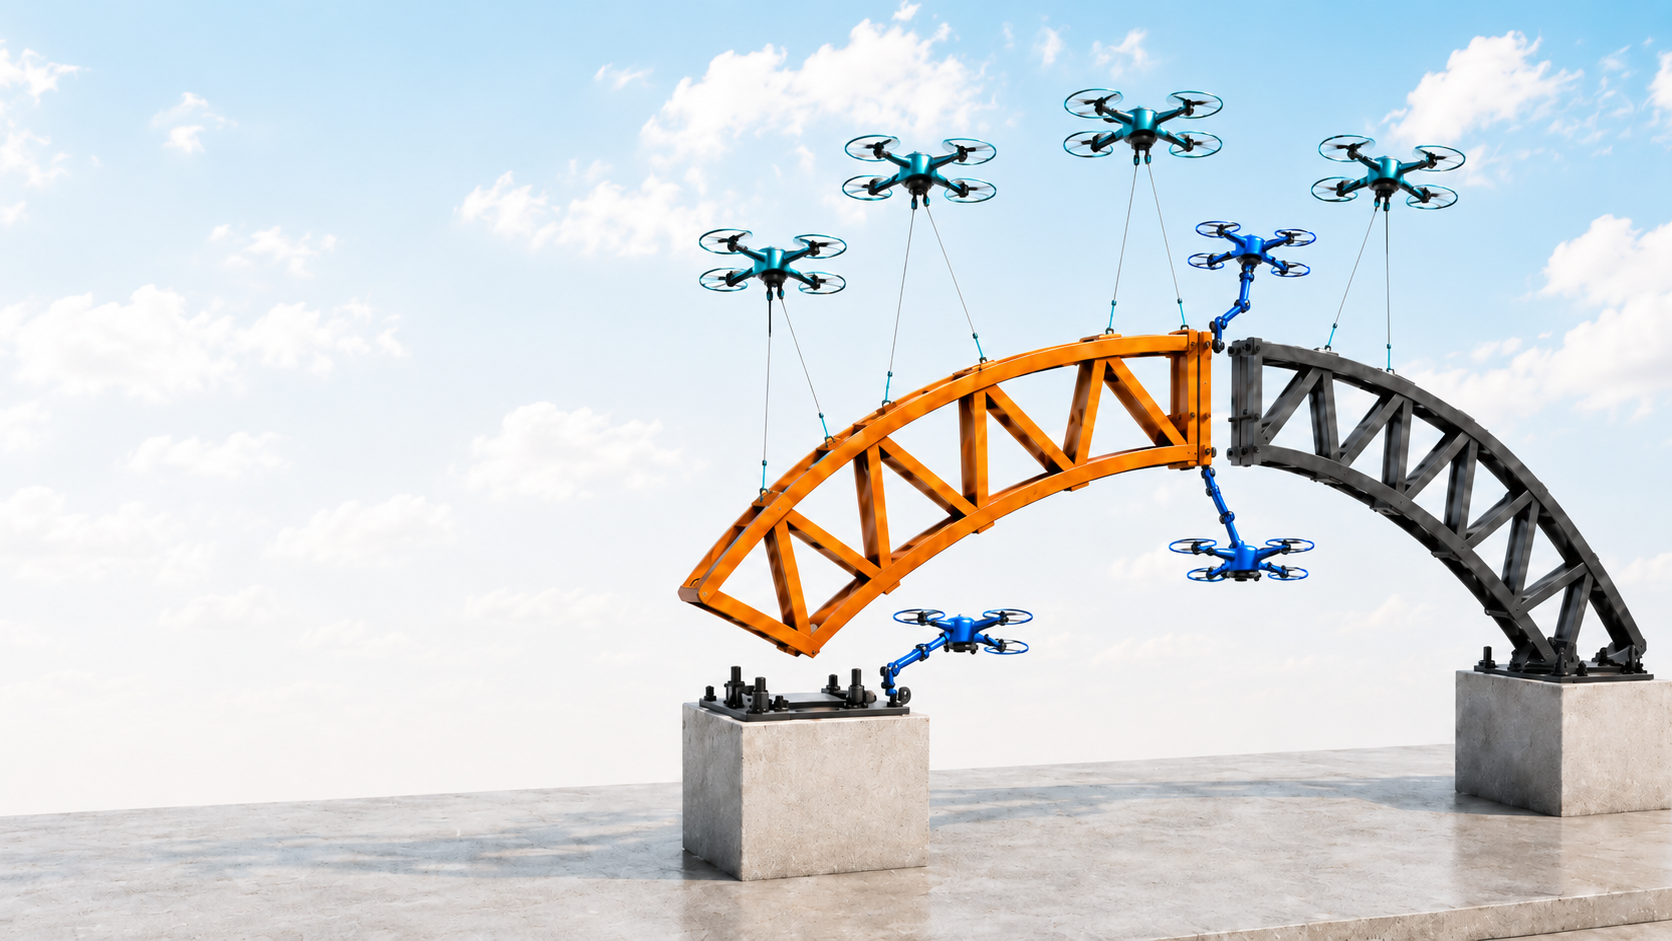
Heterogeneous aerial robot teams for in-situ prefabricated building assembly
HARPA investigates heterogeneous aerial robot teams for in-situ prefabricated building assembly. The project brings together robotic manipulation, aerial autonomy, and construction-oriented systems to explore how coordinated flying robots can support future building processes.
The project is supported through the EIC Pathfinder Challenge and is planned for 2026-2030.
Two PhD positions, one postdoc position, and one engineer position are open at TU Delft.
HARPA is hiring PhD and research associate positions at the Technical University of Munich.